All-in-one Arduino Robot
A small platform for exploring how sensors, firmware, and motor control work together. Different operating modes share the same chassis and a common set of movement commands.
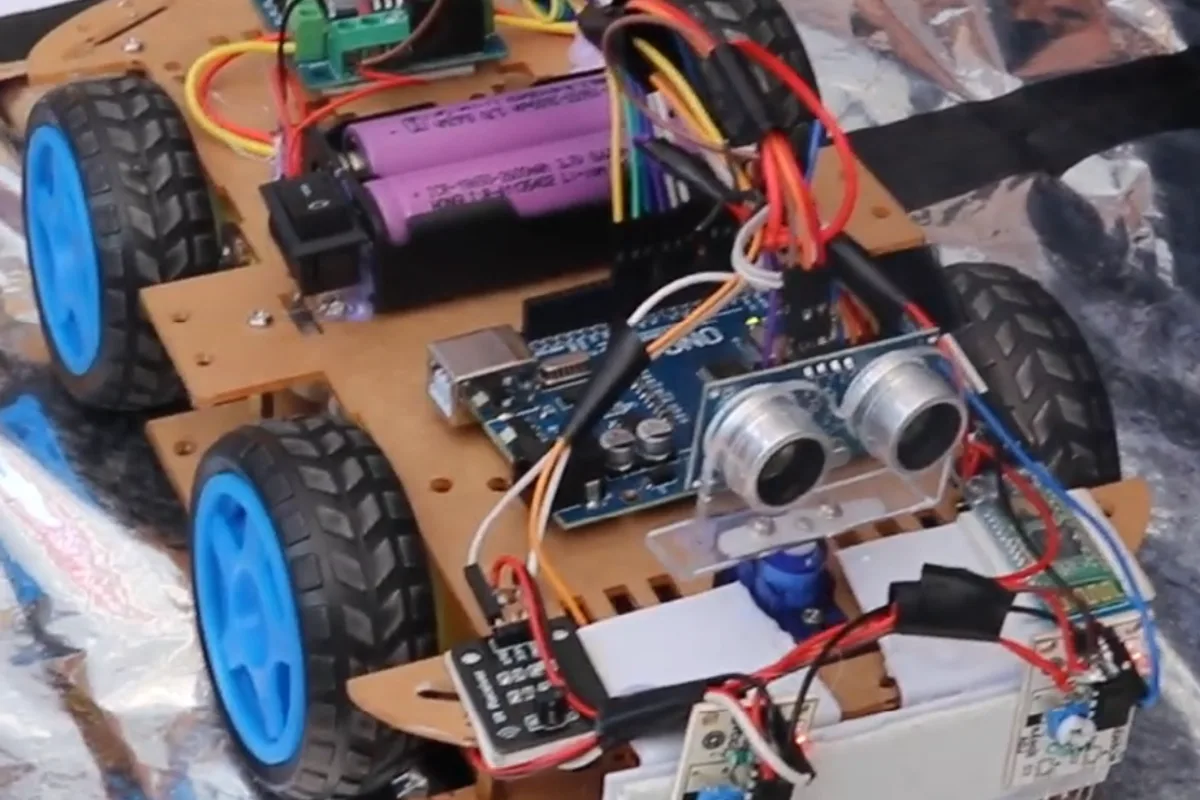
Actual build photograph
The problem
Bring several control methods into one approachable Arduino robot instead of building a separate circuit for every experiment.
Inside the implementation
The firmware reads Bluetooth and IR input, maps commands to movement functions, and switches between manual control, line following and ultrasonic obstacle avoidance. An Android app built with MIT App Inventor provides another control surface.
A common command path
Bluetooth and IR inputs map to shared movement commands. Mode selection decides which behavior controls the motors.
Simple sensing
Two IR sensors support line following. A servo-mounted ultrasonic sensor scans for space when an obstacle is detected.
A practical companion app
The repository includes the App Inventor project and Android package alongside the Arduino sketch. Voice commands come through the phone, rather than an on-device AI model.
What the evidence shows
The linked repository contains the implementation and supporting artifacts for this project. Follow the source links to inspect the details.
Current limitations
The control code includes blocking delays and fixed thresholds. The current documentation does not establish measured reliability, battery life, or repeatable navigation performance.
The next iteration
Measure the behavior across repeated line and obstacle trials, then replace blocking waits with a clearer non-blocking state machine.
Let’s build something.
Interested in robotics, an idea for a useful tool, or something we could build together? I'd like to hear about it.